Application
Robotic palletizing systems built around production flow.
PRS helps manufacturers move cases, boxes, and products through end-of-line workflows with safer, more repeatable handling and vision-verified pallet patterns.
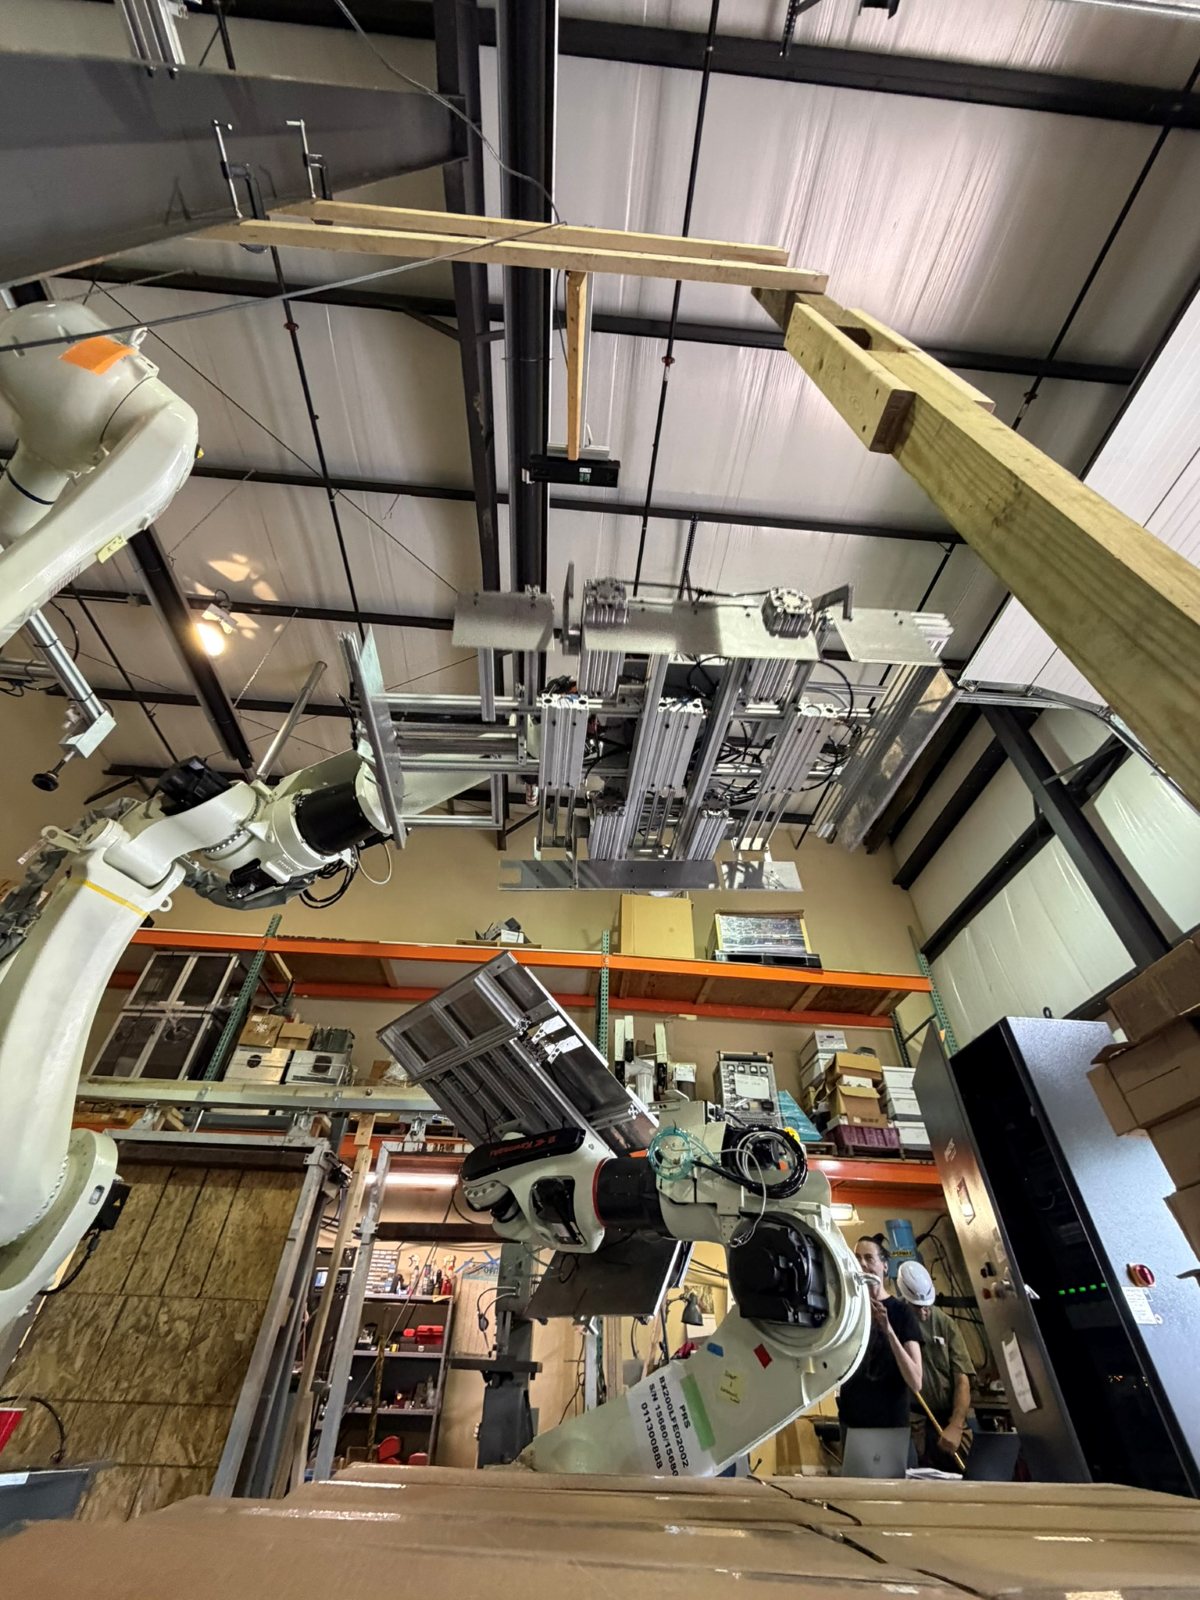
Published workcell example
Three robots coordinate layer transfer, placement, and verification.
Palletizing projects are scoped around case size, pattern requirements, line speed, floor space, robot reach, and how pallets move through the workcell.
- Kawasaki BX200L removes a full layer from a vertical frame in one pick.
- Kawasaki BX200X receives the layer, locates the pallet with Mech-Mind vision, and places the pattern.
- Kawasaki RS020N verifies the pallet pattern, detects missing or out-of-place boxes, and places layer separators.
- Full pallets convey away and new empty pallets index into position automatically.
- This published workcell runs a 15-second cycle per pallet layer. Cycle time for another application depends on the product, pattern, and layout.
Plan your workcell
Start with the case, pallet, and line.
Bring the requirements below to an evaluation so PRS can scope robot reach, handling, and pallet flow around the available space.
- Case dimensions, weight, product variation, and how cases arrive.
- Pallet dimensions, layer patterns, separators, and required stack height.
- Required line rate and how full and empty pallets enter and leave.
- Available floor space, current equipment, and operator access.
Production evaluation
Have a process that looks like this?
Share the parts, rate, constraints, current equipment, and any photos or video. PRS will help define what a practical robotic workcell should look like.
Start an evaluation