Application
Robotic case packing and packaging automation.
PRS builds case packing, blister loading, filling-line support, and end-of-line handling systems around product flow, guarding, operator access, and changeover.
Packaging workcells
Case packing with custom gripping and SKU-based recipes.
Packaging workcells can combine robots, conveyors, fixtures, case presentation, machine vision, HMI recipe control, and guarding.
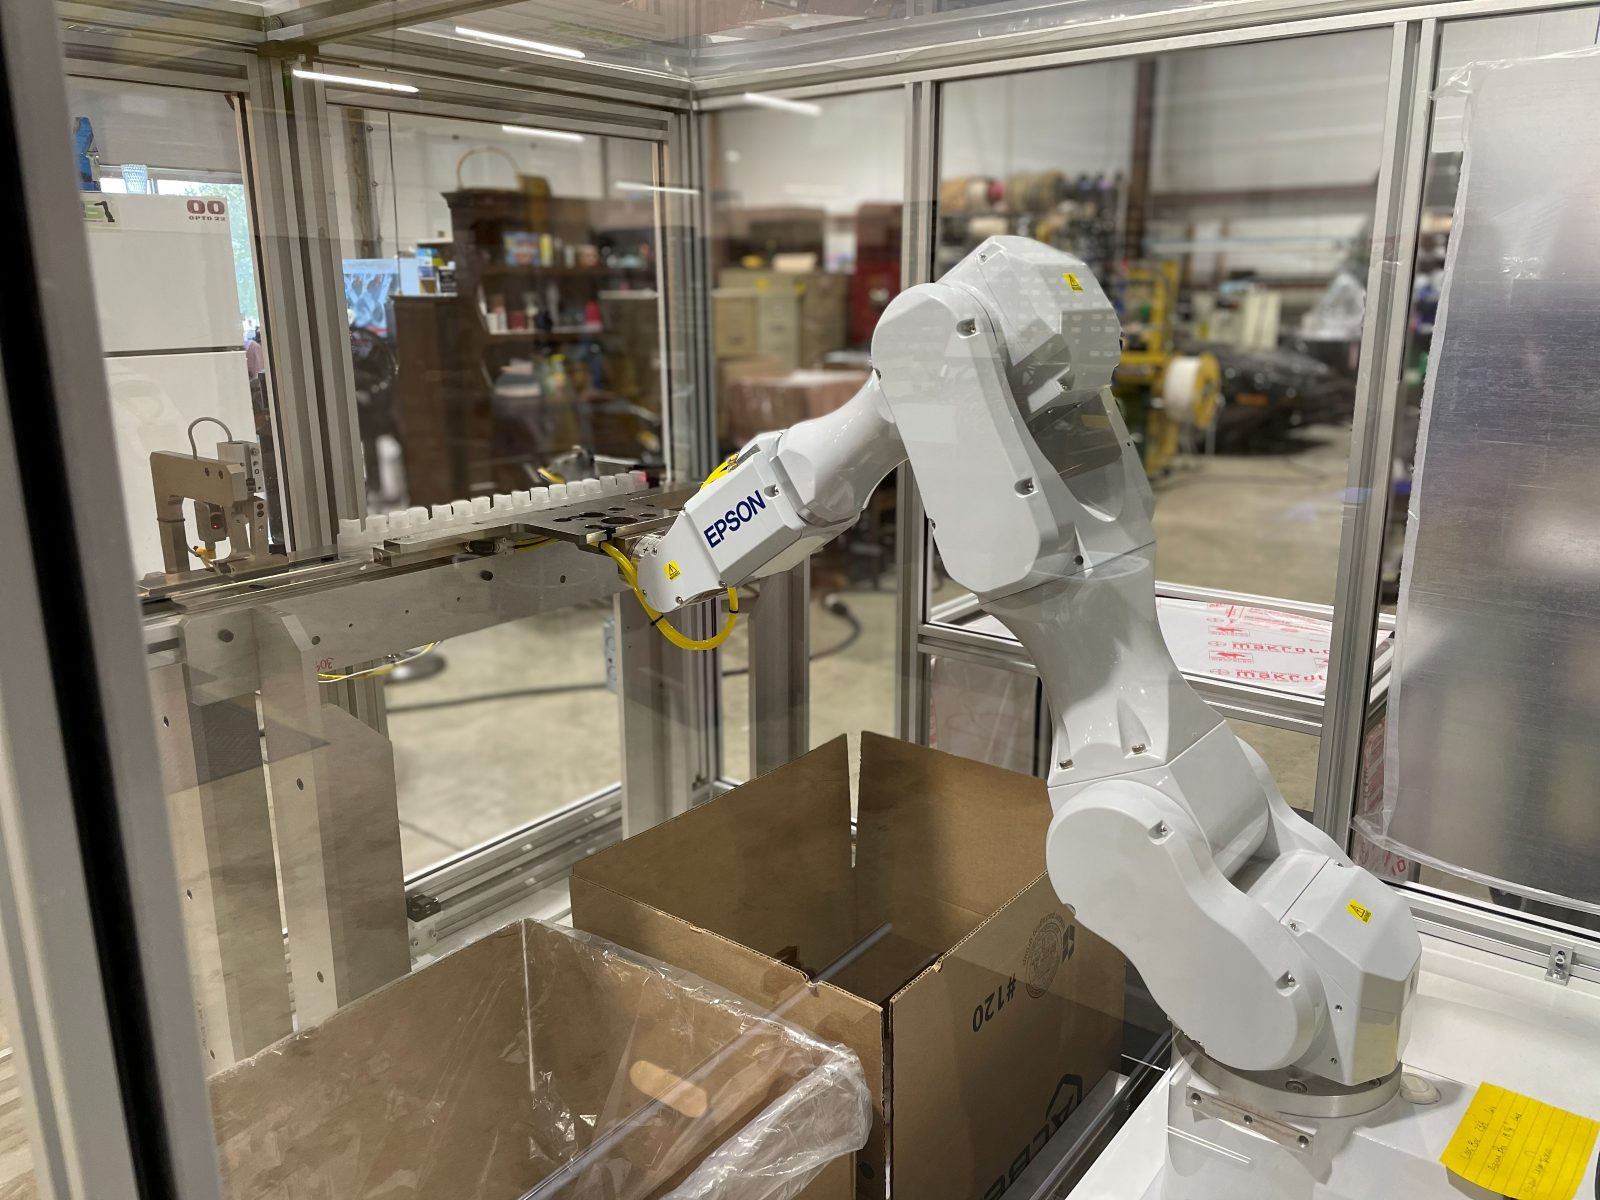
- Epson C4L case packing with custom vacuum gripping, 16-up picks, and SKU-driven layer style, layer count, and pack count.
- Blister-machine loading with two-up picking, indexed pockets, Cognex vision, and Omron Anyfeeder presentation.
- Kawasaki MS005N barrel and plunger loading for an existing filling line at 100 parts per minute.
- Full-box conveyor discharge and empty-box presentation for continuous production flow.
- Custom HMI screens for cell status, production data, recipe control, and part selection.
Case packing example
From product pick to full-case discharge.
The published Epson C4L workcell uses a custom vacuum gripper to pick 16 products at a time. SKU selection determines the layer style, layer count, and pack count. Full boxes leave on a conveyor while empty boxes are presented to the cell.
This example illustrates one product and packing arrangement. Gripping, pick quantity, and recipes are scoped for each application.
Plan your workcell
What to bring to a case-packing evaluation.
- Product dimensions, weight, orientation, and presentation.
- Case dimensions, pack pattern, layers, and SKU variations.
- Required rate, current conveyors, and space for box handling.
- Changeover needs, operator access, and photos or video of the process.
Production evaluation
Have a process that looks like this?
Share the parts, rate, constraints, current equipment, and any photos or video. PRS will help define what a practical robotic workcell should look like.
Start an evaluation